How to effectively extract image features – let’s play with...
summary
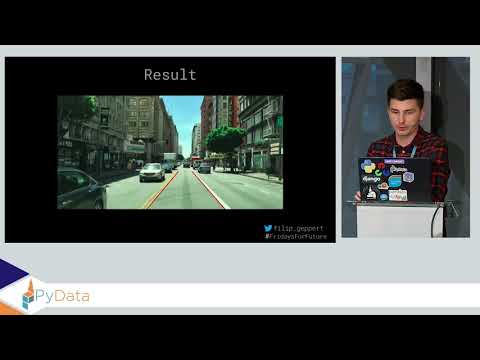
Concrete pipelines and working scripts using OpenCV 4+ pythonic API: one project builds HSV + color masks, erosion/dilation, Canny edges and HoughLinesP to detect left yellow and right white lanes; the second uses grayscale, Gaussian blur, frame differencing, thresholding and contour area filtering to produce bounding boxes for moving cars. Code and examples live on the uploader’s GitHub and the methods demonstrably detect lanes and vehicles though lighting changes cause failures, making parameter tuning essential.
AI-written summary · about
chapters (9)
- 0:00OpenCV and image features
- 1:55Color spaces and conversions
- 5:31Noise reduction with erosion/dilation
- 8:24Edge detection and line calculation
- 12:57Street line detection walkthrough
- 13:17Motion detection in video
- 17:54Car detection with bounding boxes
- 18:15Key takeaways and OpenCV recap
- 19:20OpenCV project tips
related talks
 38mFinding Lane Lines for Self Driving Cars
 46mML Use Cases at Think Big Analytics
 01h 12mBuilding a live face recognition system
 01h 11mObject detection using OpenCV
 22mShape Recognition with Computer Vision
 27mMaking PHP See
 26mDetecting and classifying object images using ruby
 17mGeoAI: a feature extraction tool set using Tensor Flow and Keras...