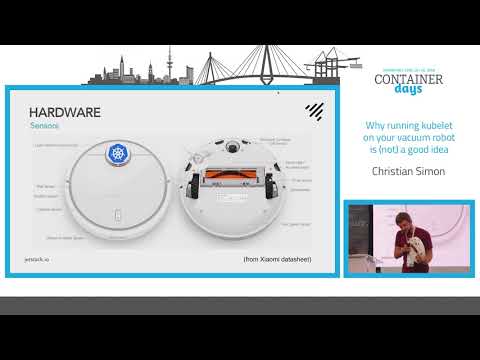
Why running kubelet on your vacuum robot is (not) a good idea
summary
Claim: running kubelet-like control on cheap robot vacuums is feasible for local scheduling and monitoring but not production-ready. Implementation uses Ubuntu 14.04 on the robot, a custom rocklet replaces cloud client that pretends to be a node, a mini API server with cronjobs to schedule cleanings, an Elm web UI, SQLite job history and PNG map conversion, and Prometheus metrics. Demo starts a cleaning successfully, but Wi‑Fi flakiness, tiny RAM, large CRD size and cloud tunneling limit reliability and scalability.
AI-written summary · about
chapters (9)
- 0:00Introduction and motivation
- 3:11Hardware and software overview
- 11:12Data privacy concerns
- 13:17Kubernetes integration approach
- 18:27Custom resource definitions
- 20:40Web UI and real-time updates
- 26:33Demo and limitations
- 27:59Future work and challenges
- 30:29Conclusion and Q&A
related talks
 33mWhy Running kubelet on your Vacuum Robot is (not) a Good Idea
 25mBuilding a PaaS for Robotics with Kubernetes
 14mReliability Engineering for Hybrid Robot-Cloud Systems
 55mTerrible Ideas in Kubernetes
 21mBuilding a PaaS for Robotics with Kubernetes
 24mAccelerating Robot Application Development with Kubernetes
 34mKubernetes at Home to Host Entertainment & Productivity Apps + More
 27mKubernetes The Fun Way